

Linear Underwater Metal Detector CEIA
Linear Underwater Metal Detector CEIA
- Extensive prospecting width per single scan
- High level of detection uniformity
- Very high stability under variations in pressure and temperature
Product Specifications
| Active Search Area | 1150 mm × 900 mm |
|---|---|
| Antenna Protection | Rigid plastic housing with resin-sealed antenna windings |
| Antenna Type | Bi-static planar transmitter/receiver antenna |
| Applications | Subsea surveys / underwater security / seabed metal detection / mine and UXO search / ROV-based inspection / naval and defence operations |
| Buoyancy | Mechanical framework designed to achieve underwater balance through hydrostatic buoyancy of hollow structural elements |
| Data Transmission | Digital transmission of detection/prospecting data to a surface processing and mapping unit |
| Detection Capability | Detection of both magnetic and non-magnetic metallic targets |
| Detection Method | Dynamic and static detection |
| Detection Technology | Low-frequency electromagnetic induction using a bi-static transmitter/receiver planar antenna |
| Detection Uniformity | High detection uniformity across the active antenna area |
| Detection Zones | Single detection zone |
| Electronics Housing | Resin-sealed electronics inside an AISI 316 stainless-steel container |
| Environmental Stability | High stability under variations in underwater pressure and temperature |
| Key Advantage | Provides a relatively wide detection area per scan while maintaining uniform detection sensitivity and stable operation in changing underwater pressure and temperature conditions |
| Manoeuvrability | Designed for easy underwater movement and positioning |
| Manufacturer | CEIA |
| Mechanical Structure | AISI 316 stainless-steel tubular framework |
| Operating Environment | Underwater environments and submarine operations |
| Power Supply | DC power supplied directly by the ROV |
| Primary Application | Underwater metal detection and submarine/ROV survey operations |
| Product Name | CEIA Linear Underwater Metal Detector |
| Product Type | Single-Zone Underwater Electromagnetic Induction (EMI) Metal Detector |
| Prospecting Width | Extensive search width for a single scan |
| ROV Connection | High-pressure-rated cables connecting the antenna and electronics to the ROV |
| ROV Integration | Designed for mounting on a remotely operated vehicle (ROV) |
| Surface Control | Detector operation controlled from the surface vessel through the ROV connection |
| Target Materials | Magnetic metals / non-magnetic metals / metallic buried or submerged objects |
| Visual Support | Can operate together with ROV lights and cameras to identify visible objects and avoid obstacles |
Linear Underwater Metal Detector CEIA
- Extensive prospecting width per single scan
- High level of detection uniformity
- Very high stability under variations in pressure and temperature
- Dynamic and static detection
- Digital transmission of prospecting data to a processing and mapping unit on the surface
- Excellent manoeuverability and ease of use
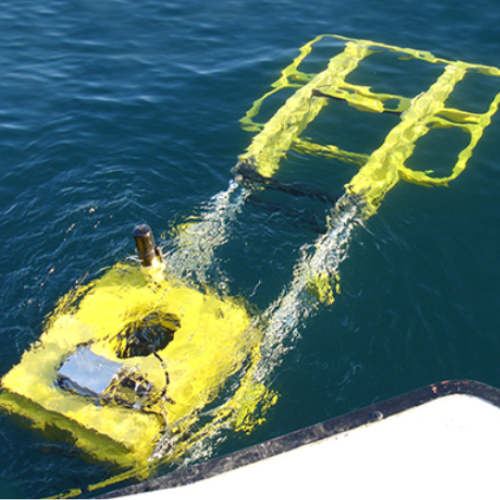
In 2006 the design of a first underwater large coil metal detector was started. The engineering phase was completed in early 2007 with the production release of the equipment. The unit is a single zone EMI Metal Detector based on a bi-static Transmitter/Receiver planar antenna with an active surface area of 1150mm (W) x 900mm (L).
The antenna windings are protected inside a rigid plastic housing sealed with resin and mounted to the structure of a ROV with a framework of tubing made of AISI316 Stainless Steel. This structure is calculated to be balanced underwater by the hydrostatic buoyancy of the hollow parts.
The electronics unit, sealed with resin inside a 316 SS container, is connected to the antenna array by a cable suitable for operations under high pressure; a second cable with similar characteristics provides DC power to the antenna. The power is directly supplied by the ROV.
The detection system is based on the transmission and receiving of a low frequency electromagnetic field and it is tuned to detect targets made of magnetic and nonmagnetic metals.
The operation of the detector can be controlled from a surface vessel connected to the ROV by a cable and assisted by a system of lights and cameras allowing to see visible objects and avoid obstacles like wood trunks and rocks.